Xiang ZhuI am a Ph.D. candidate (successive postgraduate and doctoral programs) at the Institute for Interdisciplinary Information Sciences, Tsinghua University, advised by Prof. Jianyu Chen. I expect to graduate in June 2027. Prior to that, I received my Bachelor's degree from the School of Automation, Beijing University of Posts and Telecommunications. |
|
ResearchMy research focuses on embodied AI and robot learning, with a particular interest in leveraging human data to improve robot manipulation. Recently, I have been exploring Vision-Language-Action (VLA) models, World-Action Models (WAMs), and cross-embodiment learning to enable more generalizable robot policies through human-robot knowledge transfer. I am also interested in dexterous manipulation, humanoid robotics, reinforcement learning, and sim-to-real transfer. (*: Equal contribution. Co-first Author.) |
|
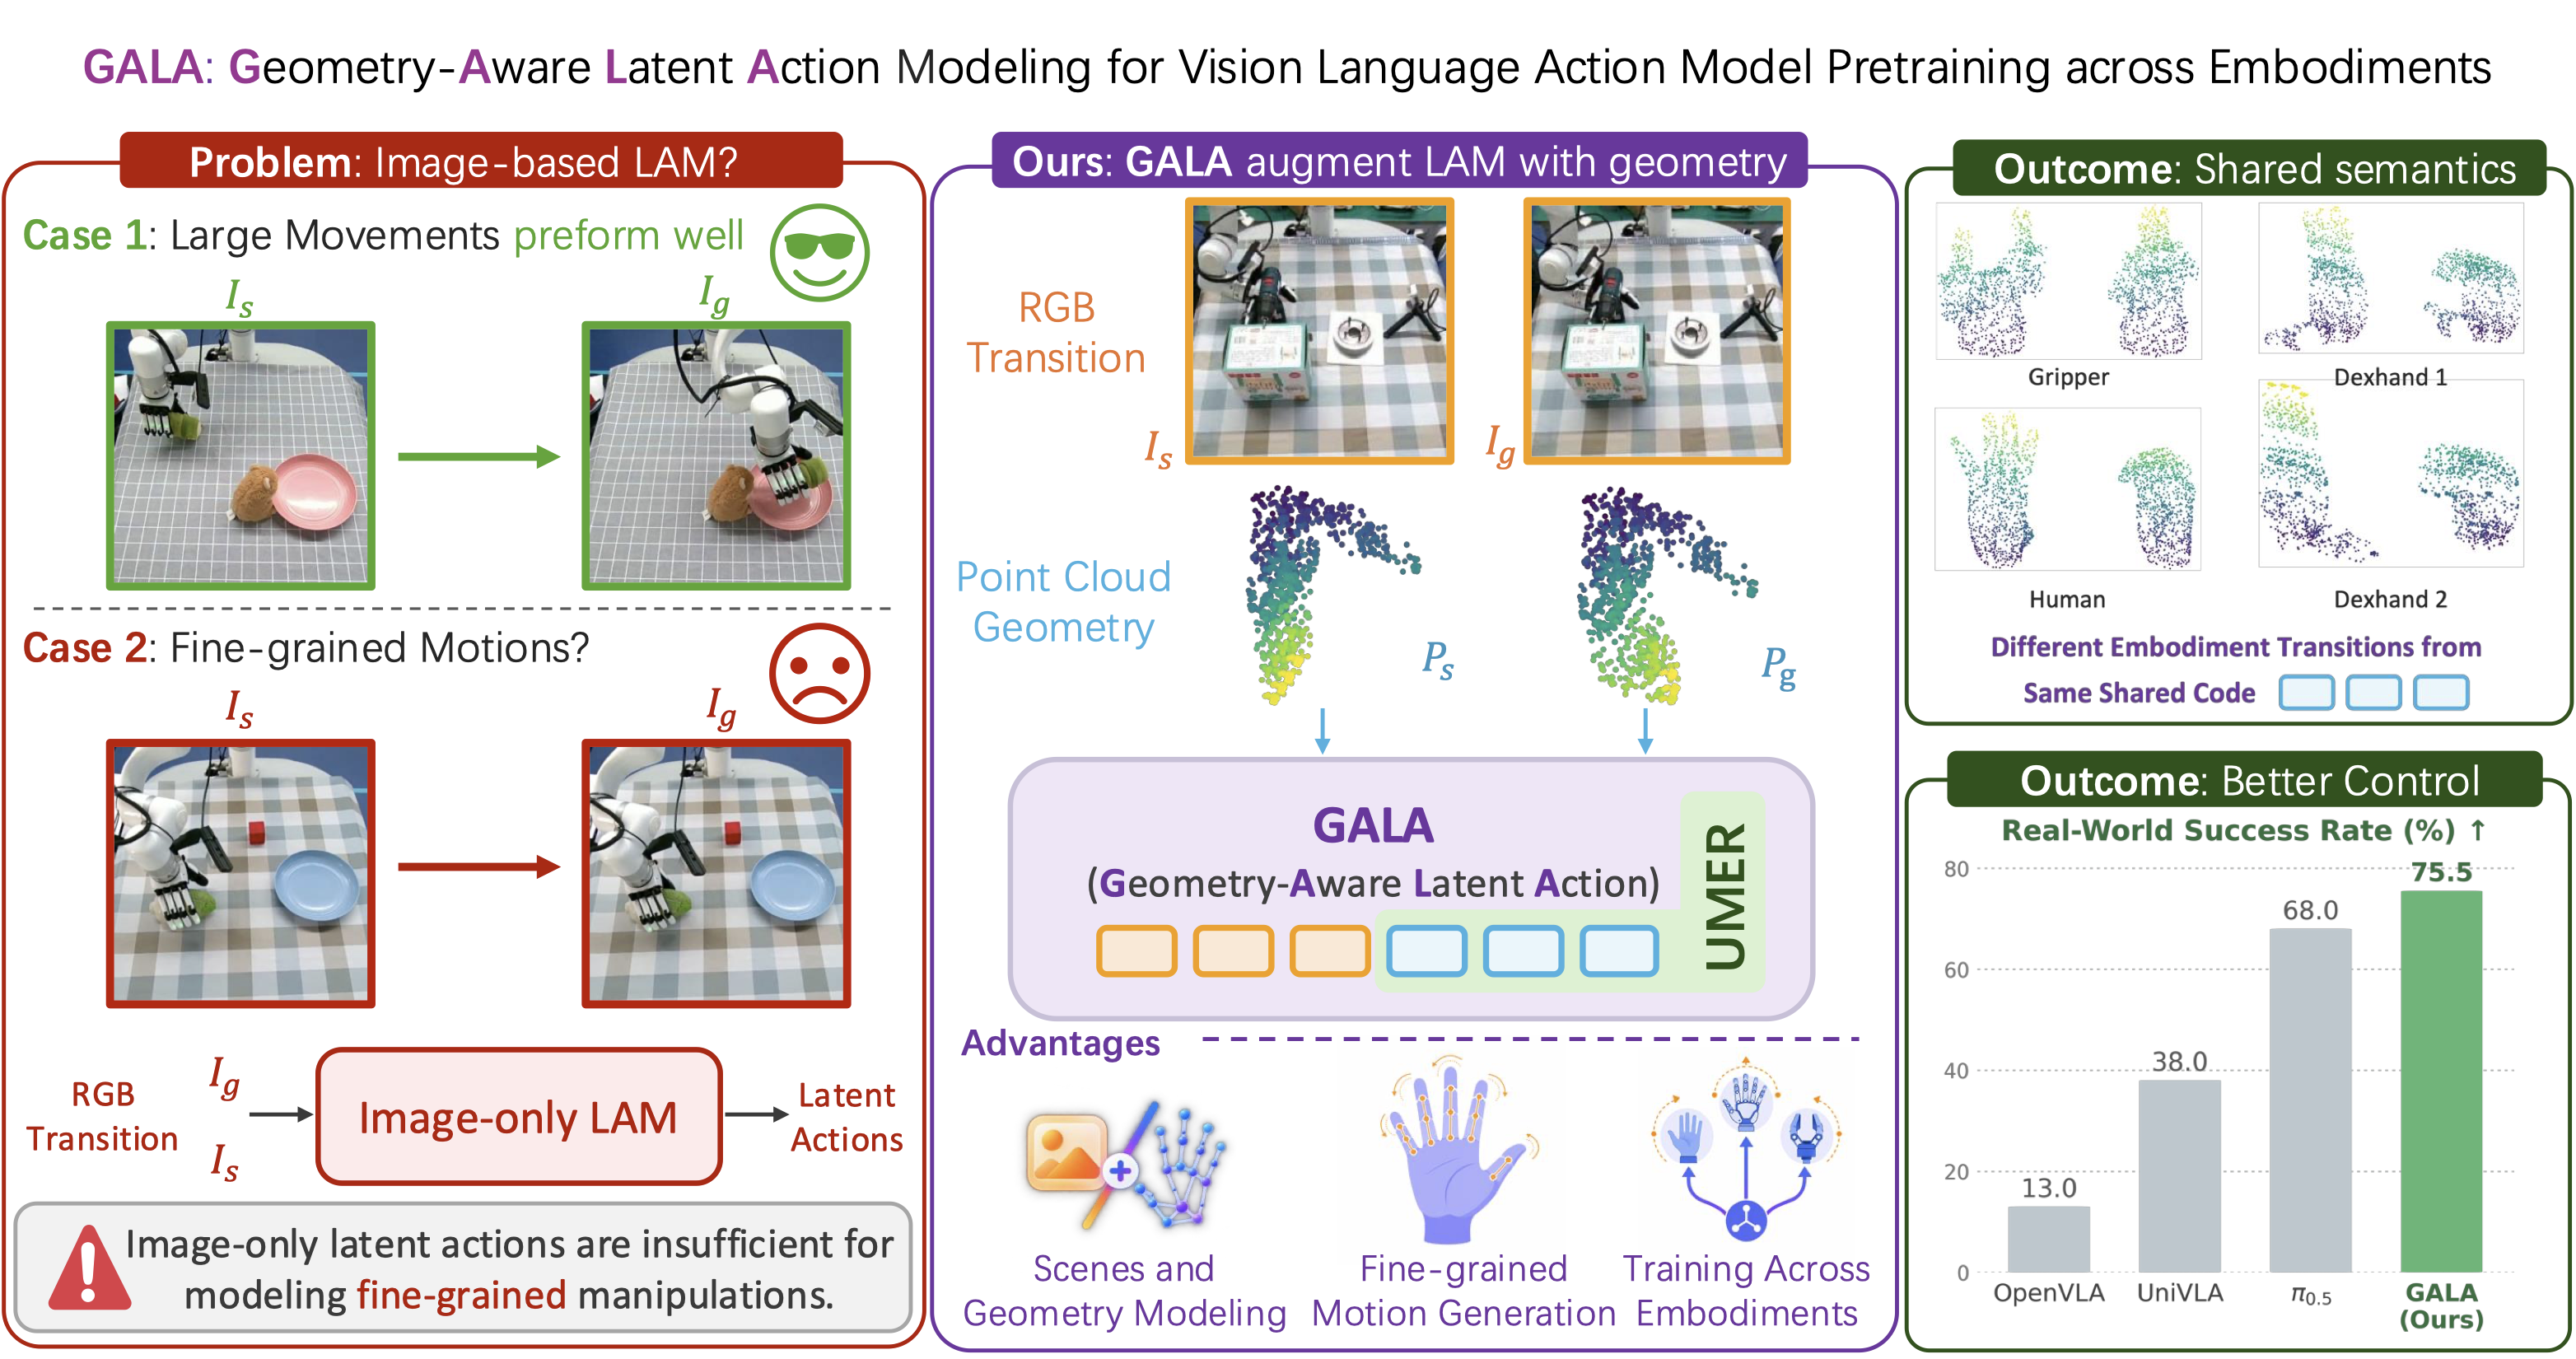
GALA: Geometry-Aware Latent Action Modeling for Vision-Language-Action Model Pretraining across Embodiments Xiang Zhu*, Puzhen Yuan*, Yichen Liu*, Yanjing Guo, Jianyu Chenunder review at ICRA 2027, 2026 pdf / |
|
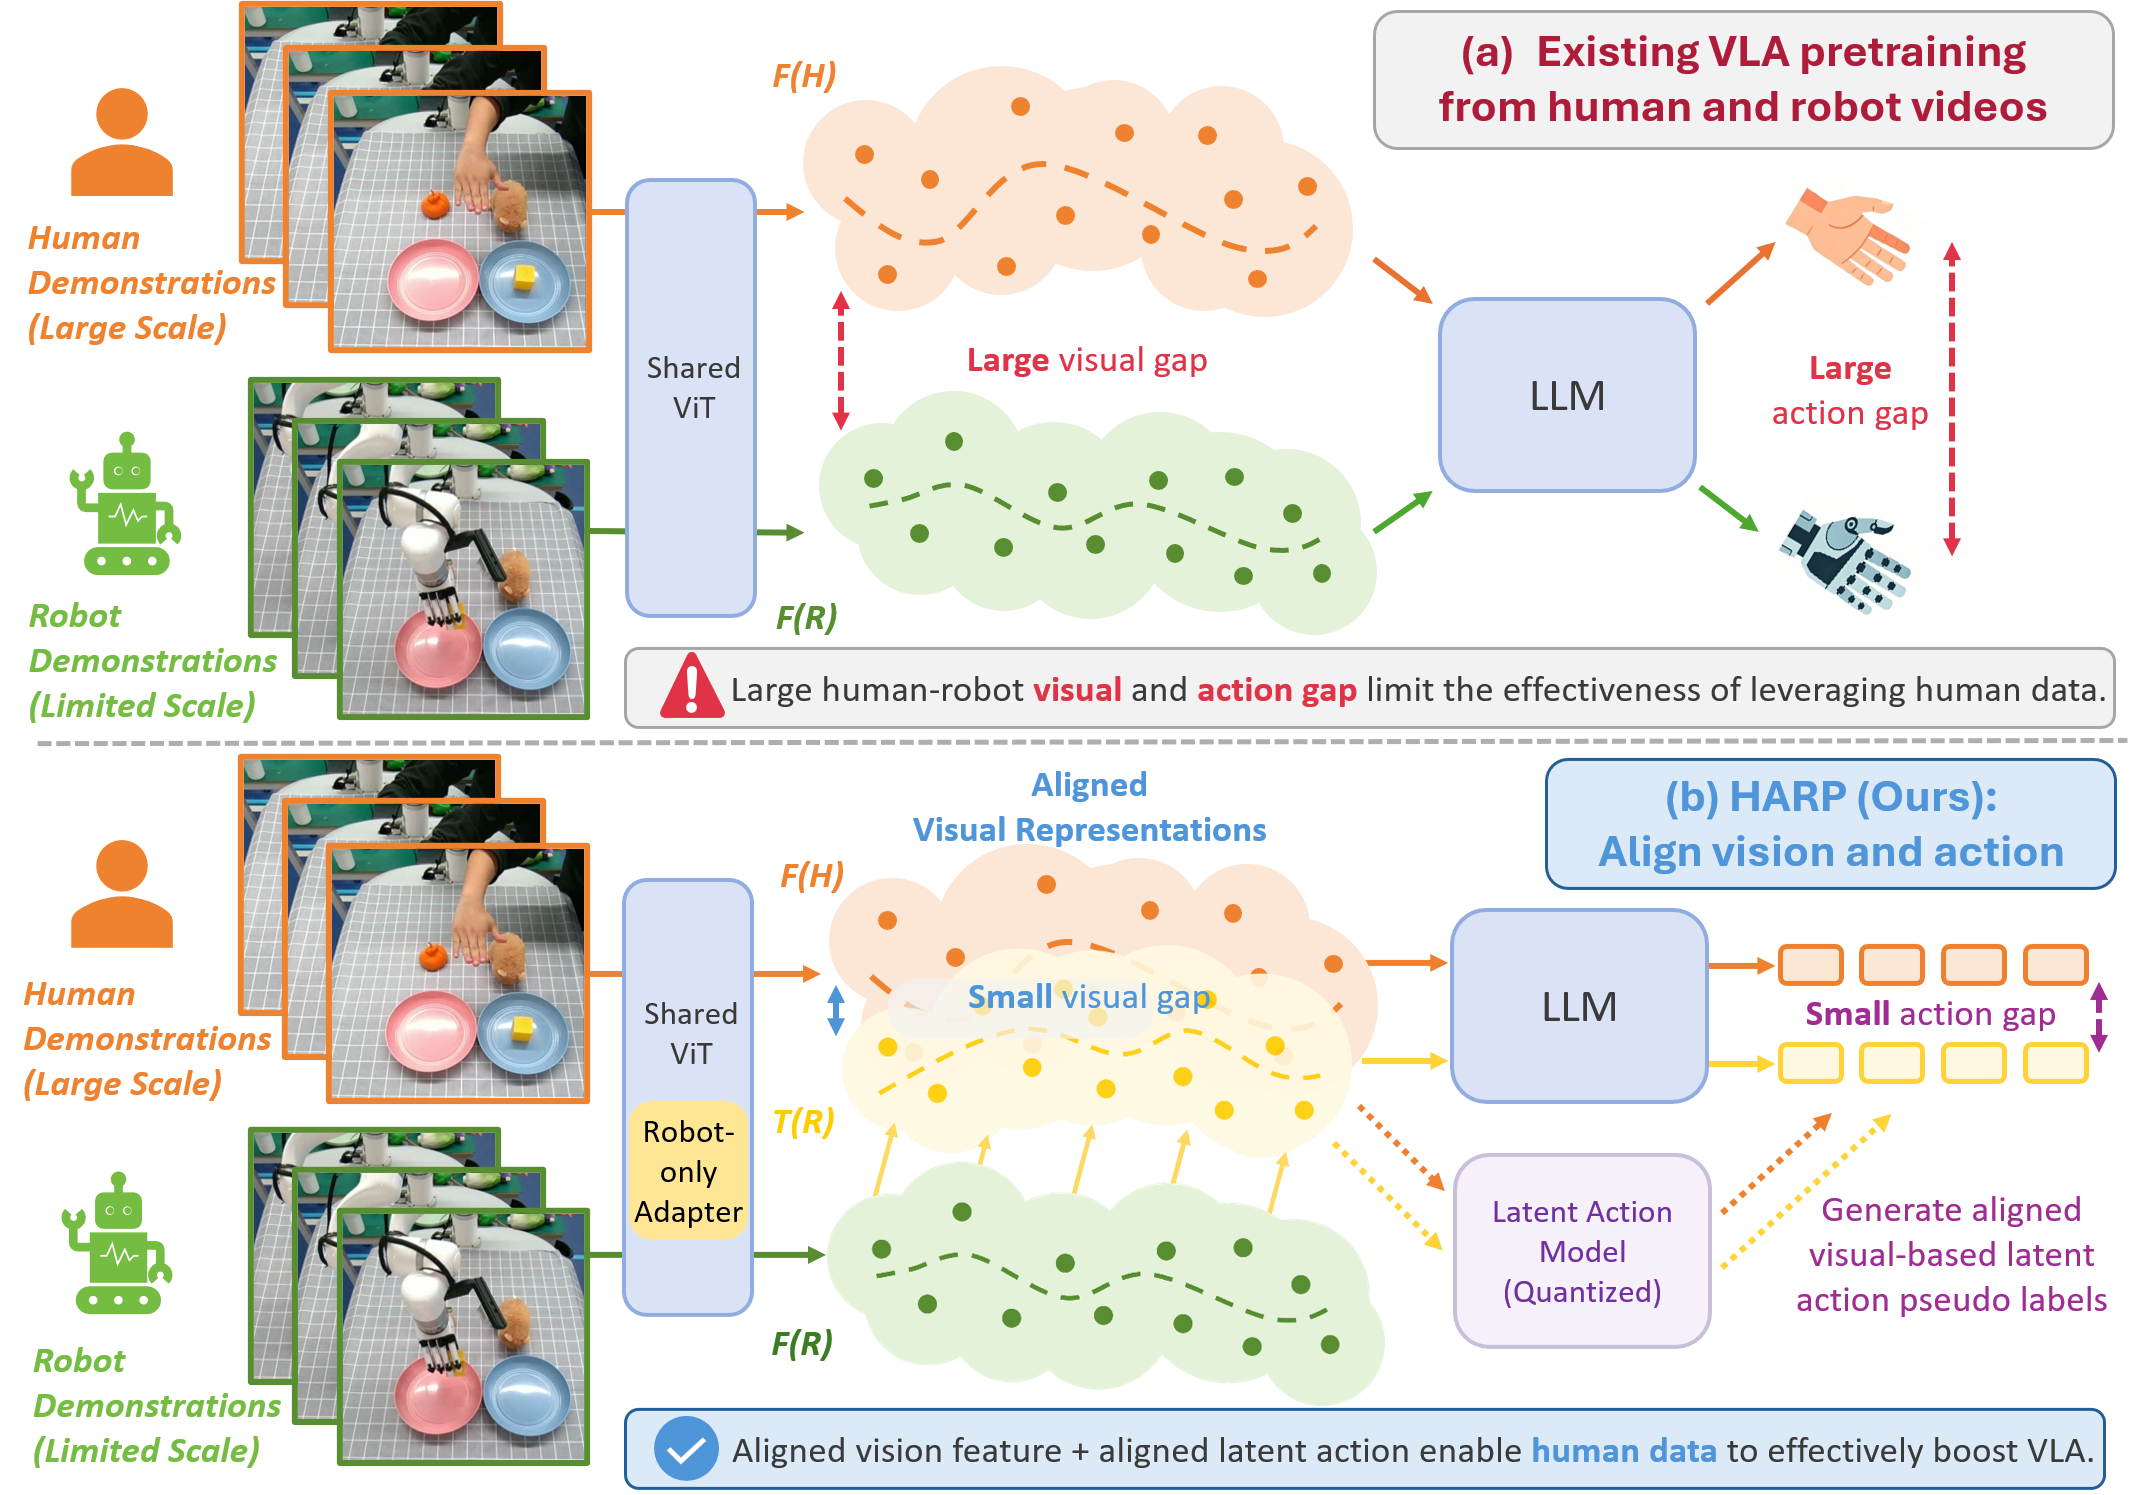
HARP-VLA: Human-Robot Aligned Representation Learning for Vision-Language-Action Model Xiang Zhu, Puzhen Yuan, Yichen Liu, Jianyu ChenCoRL 2026, 2026 pdf / |
|
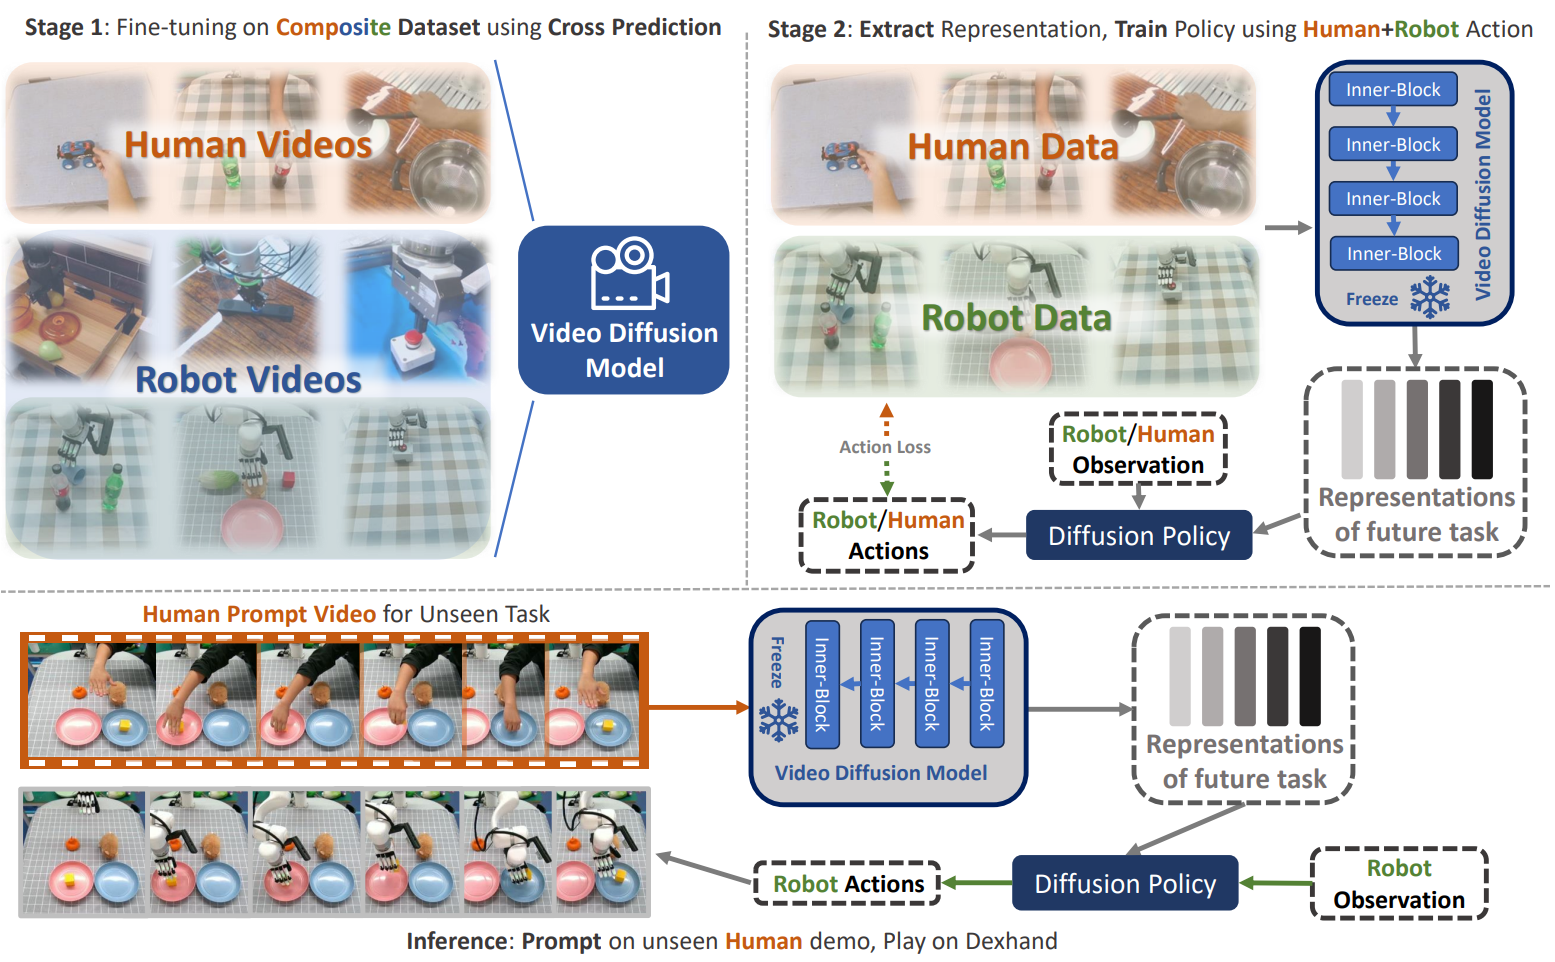
Learning Generalizable Robot Policy with Human Demonstration Video as a Prompt Xiang Zhu, Yichen Liu, Hezhong Li, Jianyu ChenICRA 2026, 2025 pdf / |
|
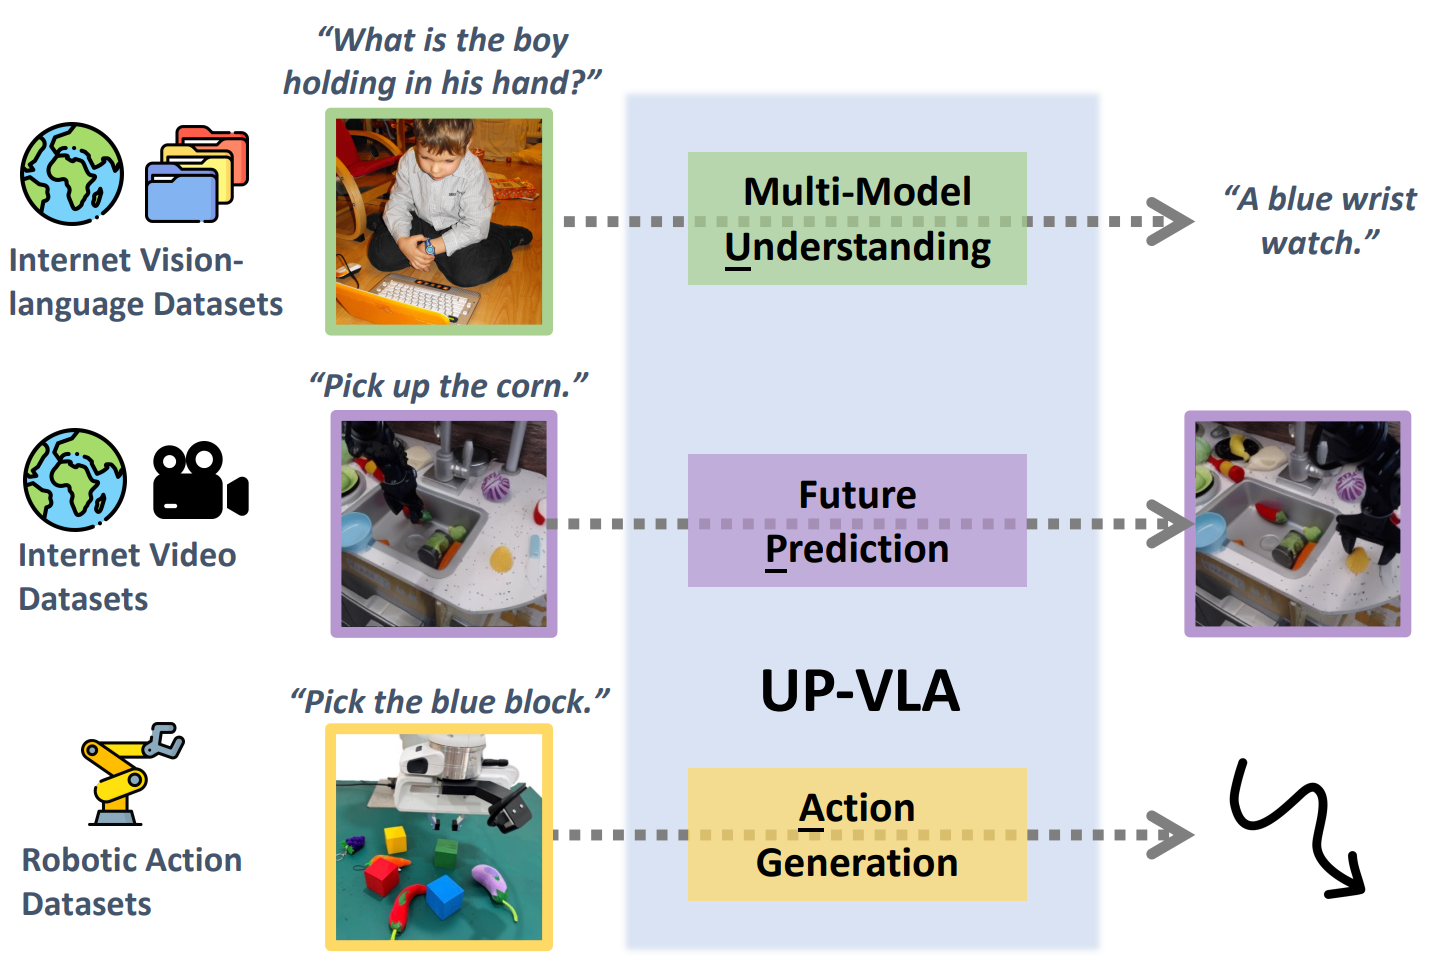
UP-VLA: A Unified Understanding and Prediction Model for Embodied Agent Jianke Zhang, Yanjiang Guo, Yucheng Hu, Xiaoyu Chen, Xiang Zhu, Jianyu ChenInternational Conference on Machine Learning(ICML), 2025 pdf / |
|
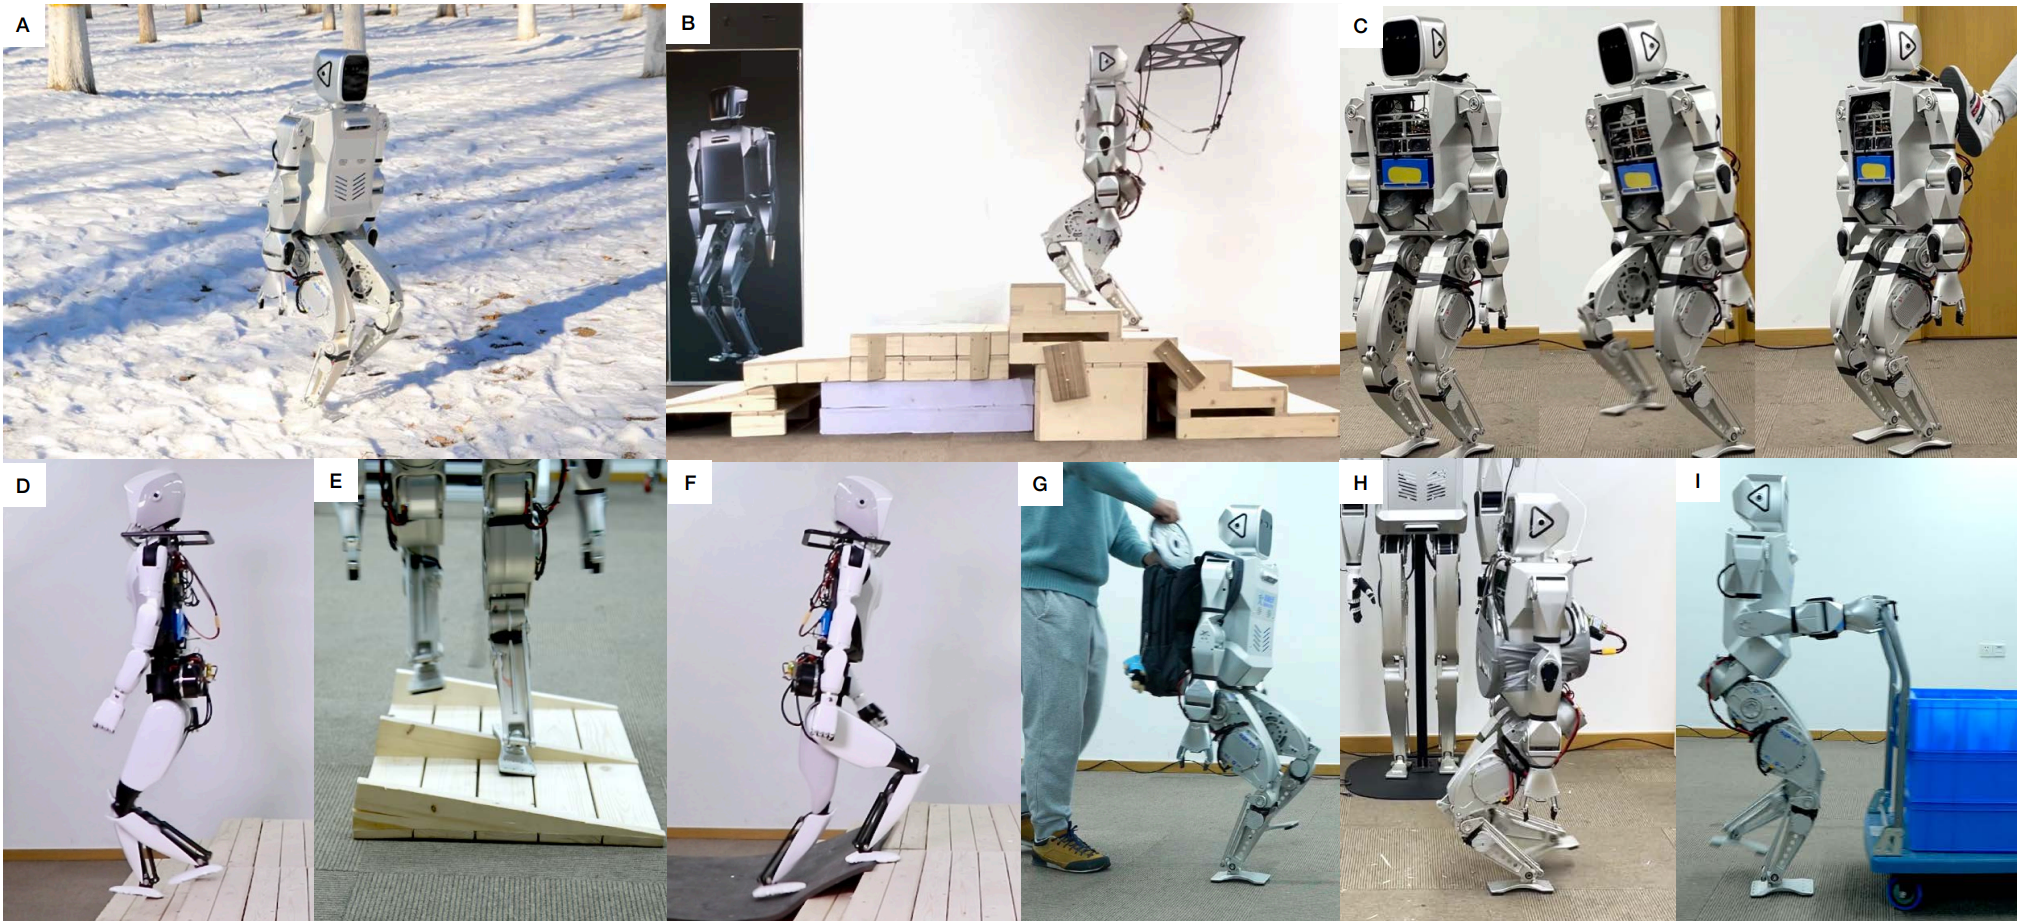
Advancing humanoid locomotion: Mastering challenging terrains with denoising world model learning Xinyang Gu*, Yen-Jen Wang*, Xiang Zhu*, Chengming Shi*, Yanjiang Guo, Yichen Liu, Jianyu ChenRobotics: Science and Systems (RSS), 2024 pdf / code / Best Paper Award Finalists. |
|
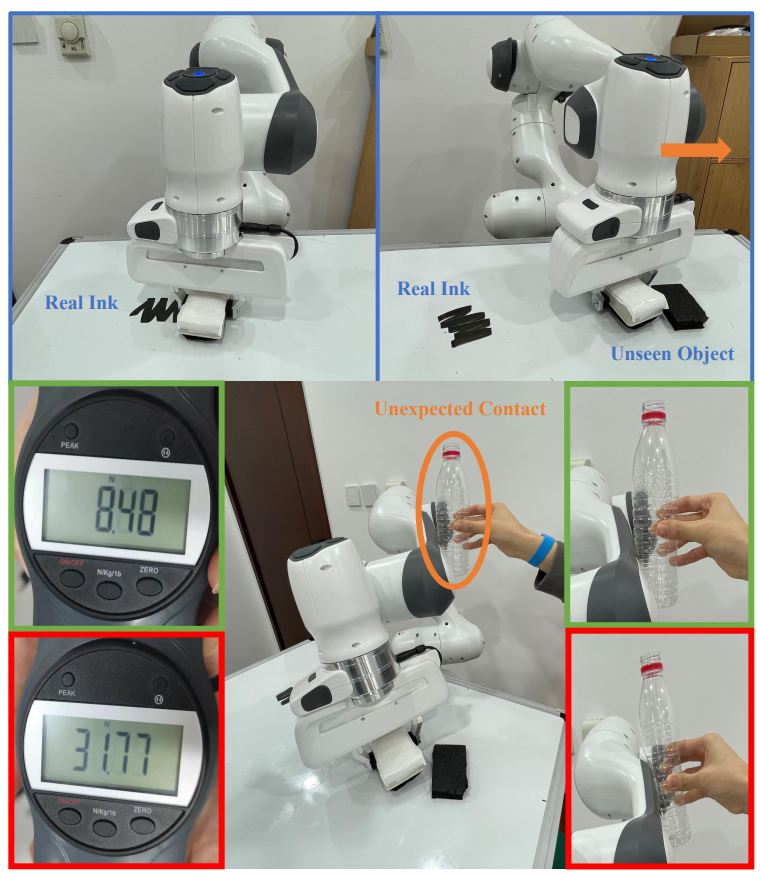
A Contact-Safe Reinforcement Learning Framework for Contact-Rich Robot Manipulation Xiang Zhu, Zixuan Chen, Jianyu ChenarXiv preprint, 2023 pdf / |
|
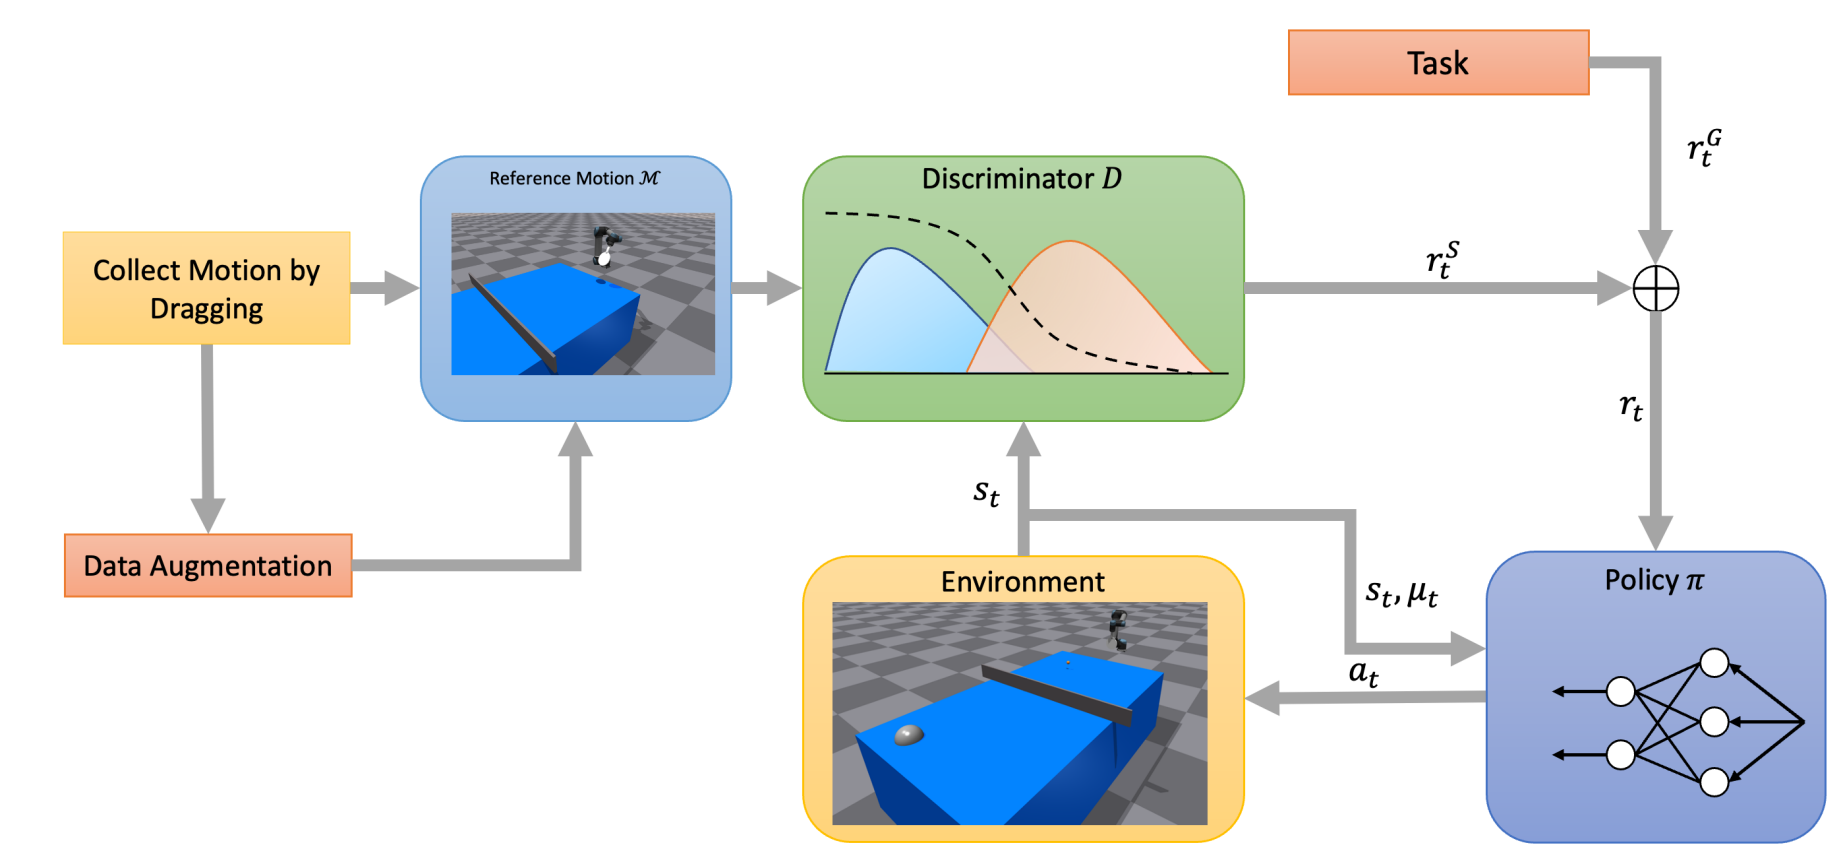
Stylized table tennis robots skill learning with incomplete human demonstrations Xiang Zhu, Shucheng Kang, Jianyu ChenInternational Conference on Intelligent Robots and Systems (IROS), 2022 pdf / |
|
Design and source code from Jon Barron's website |